DARPA Robotics Challenge
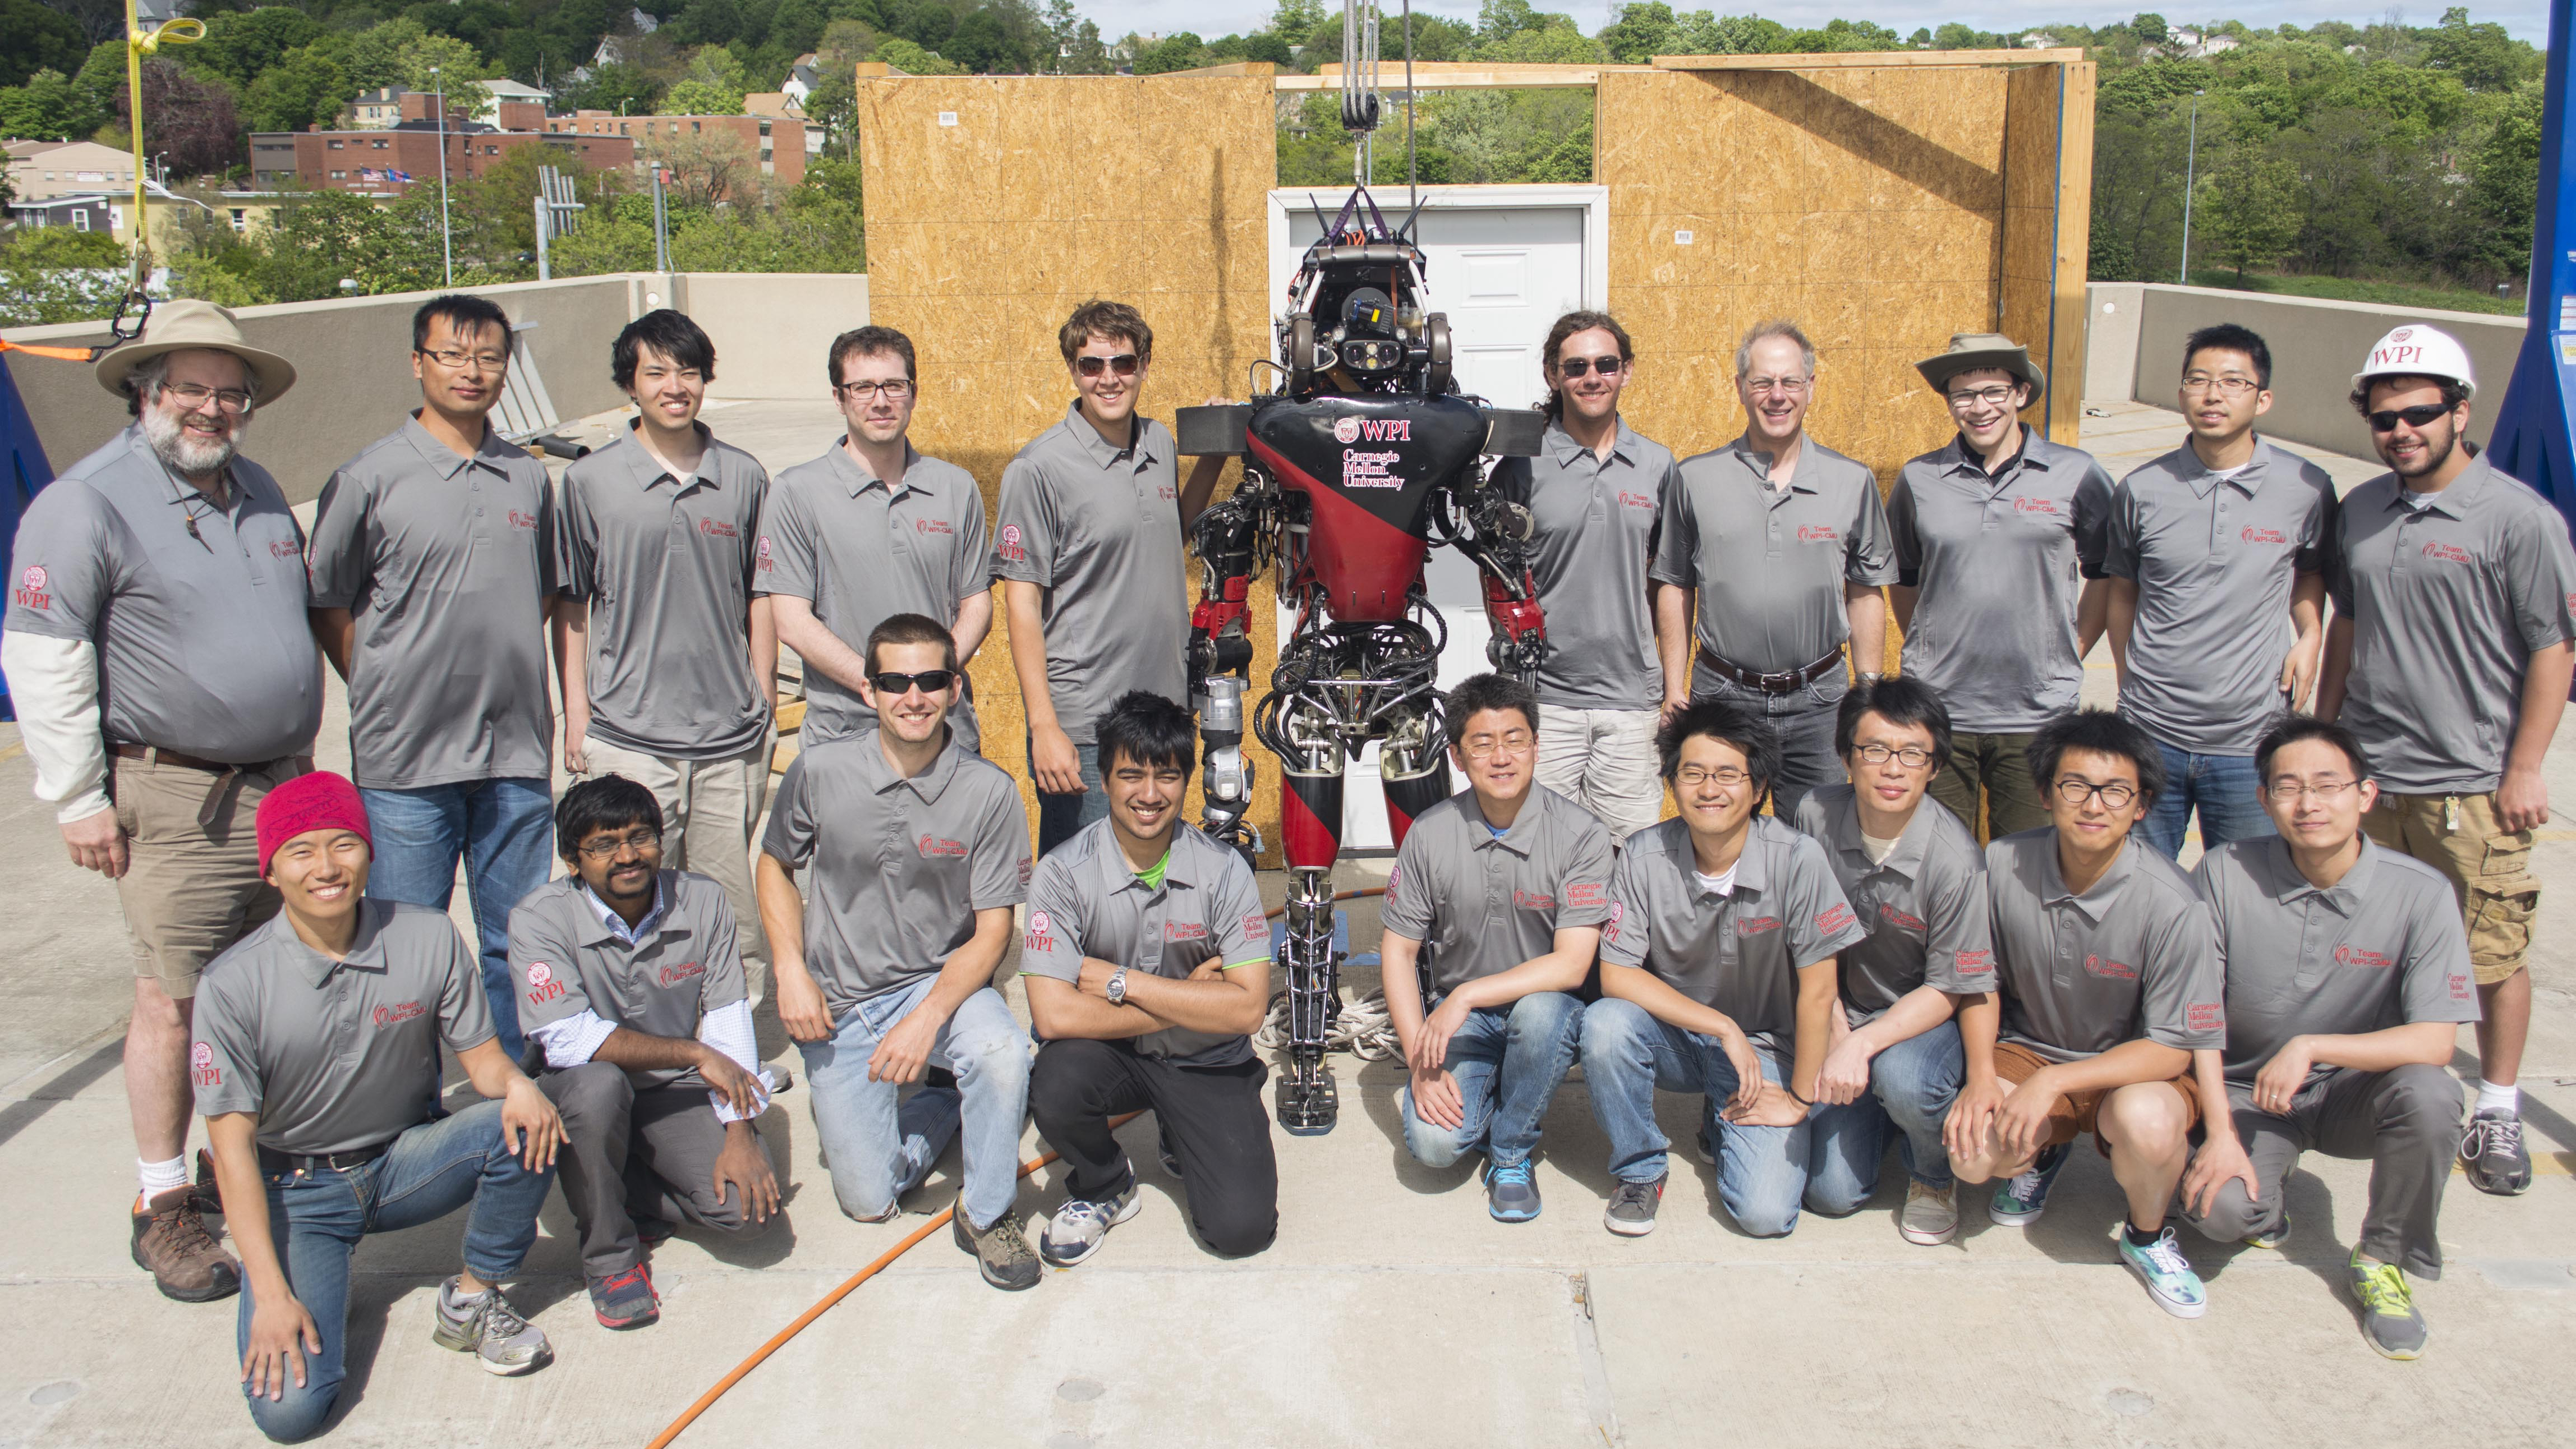
The DARPA Robotics Challenge (DRC) sought human-supervised ground robots able to execute complex tasks in dangerous, degraded environments — disaster scenarios too hazardous for a timely human response. Trials were held in December 2013 and the Finals in June 2015; see the DRC program archive.
As a member of Team WPI-CMU I designed a motion planner for arm manipulation — door opening, valve turning, tool grasping — and a human-robot interaction interface that improved operator situational awareness. The team finished 7th of 24.
Photographs
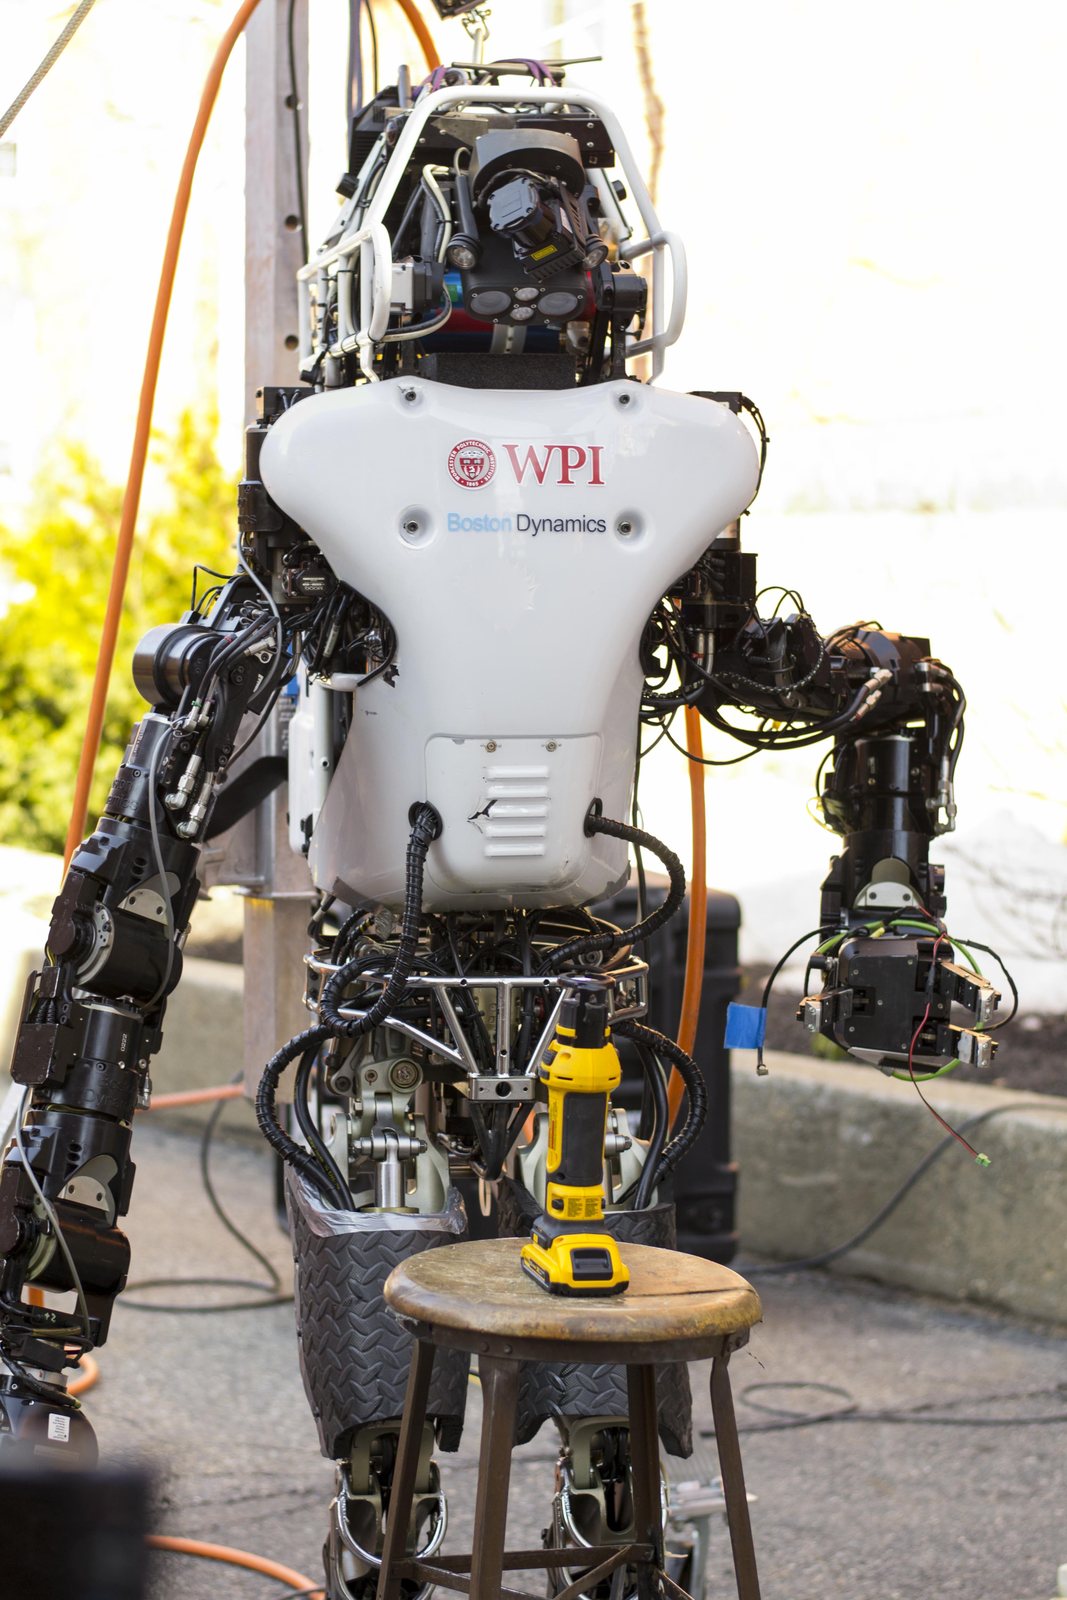
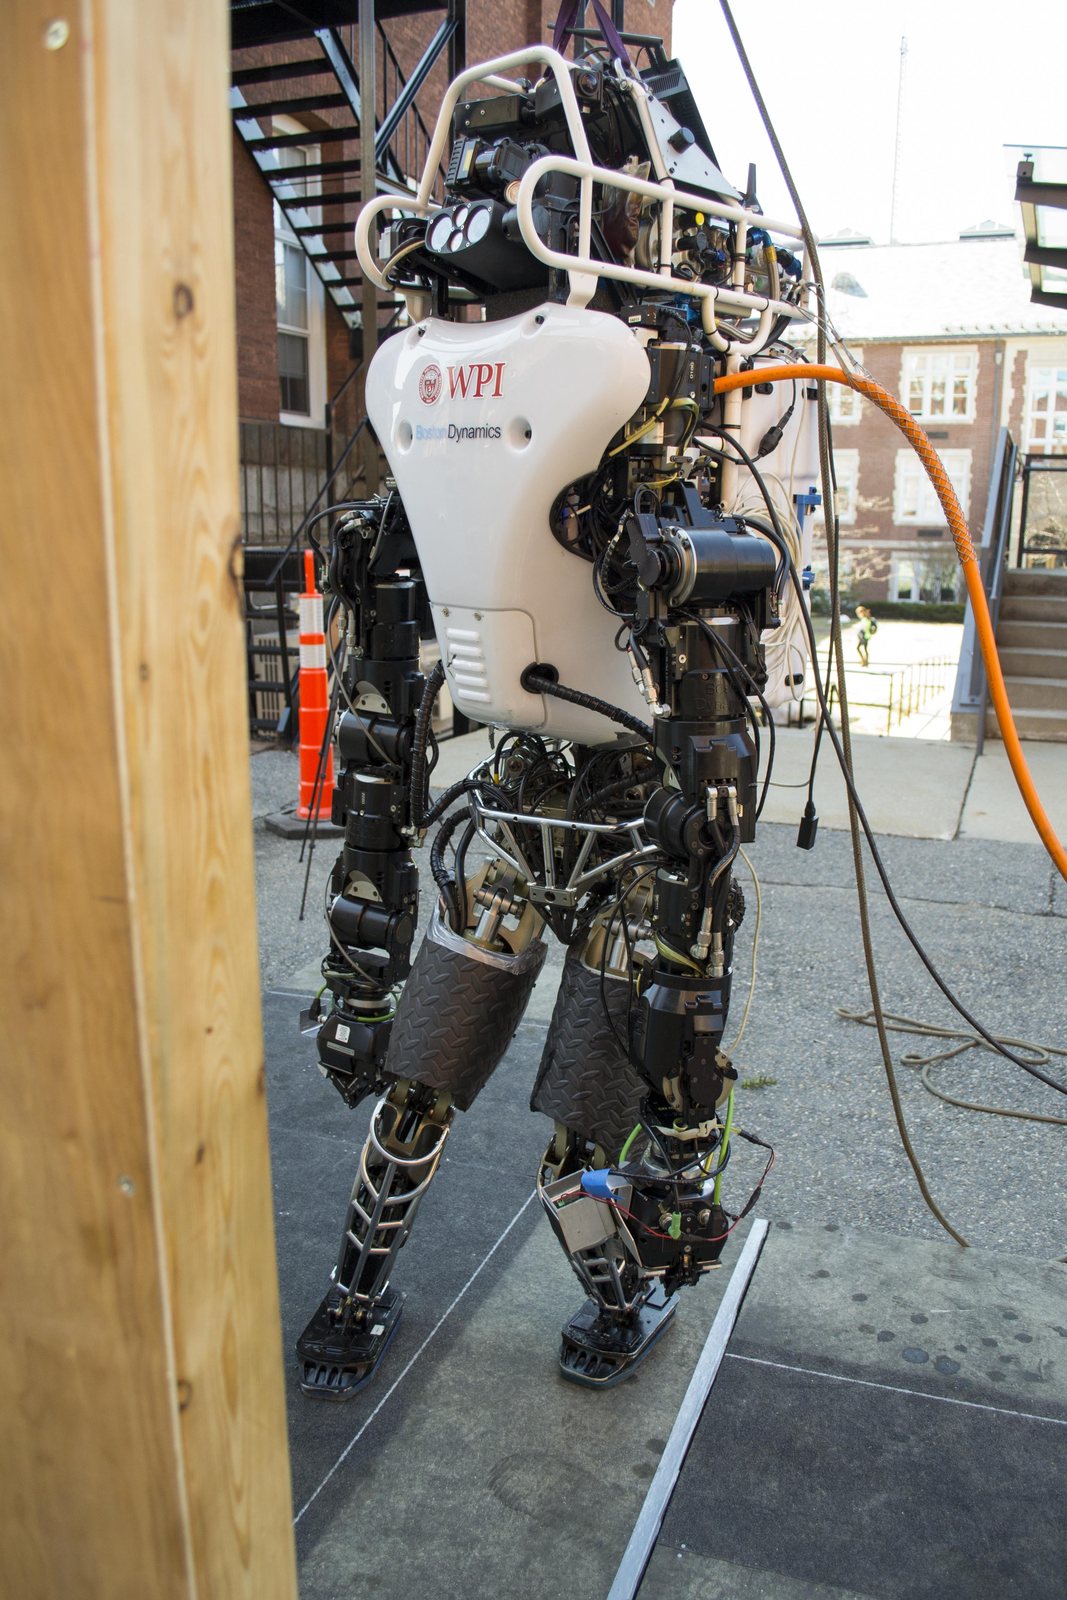
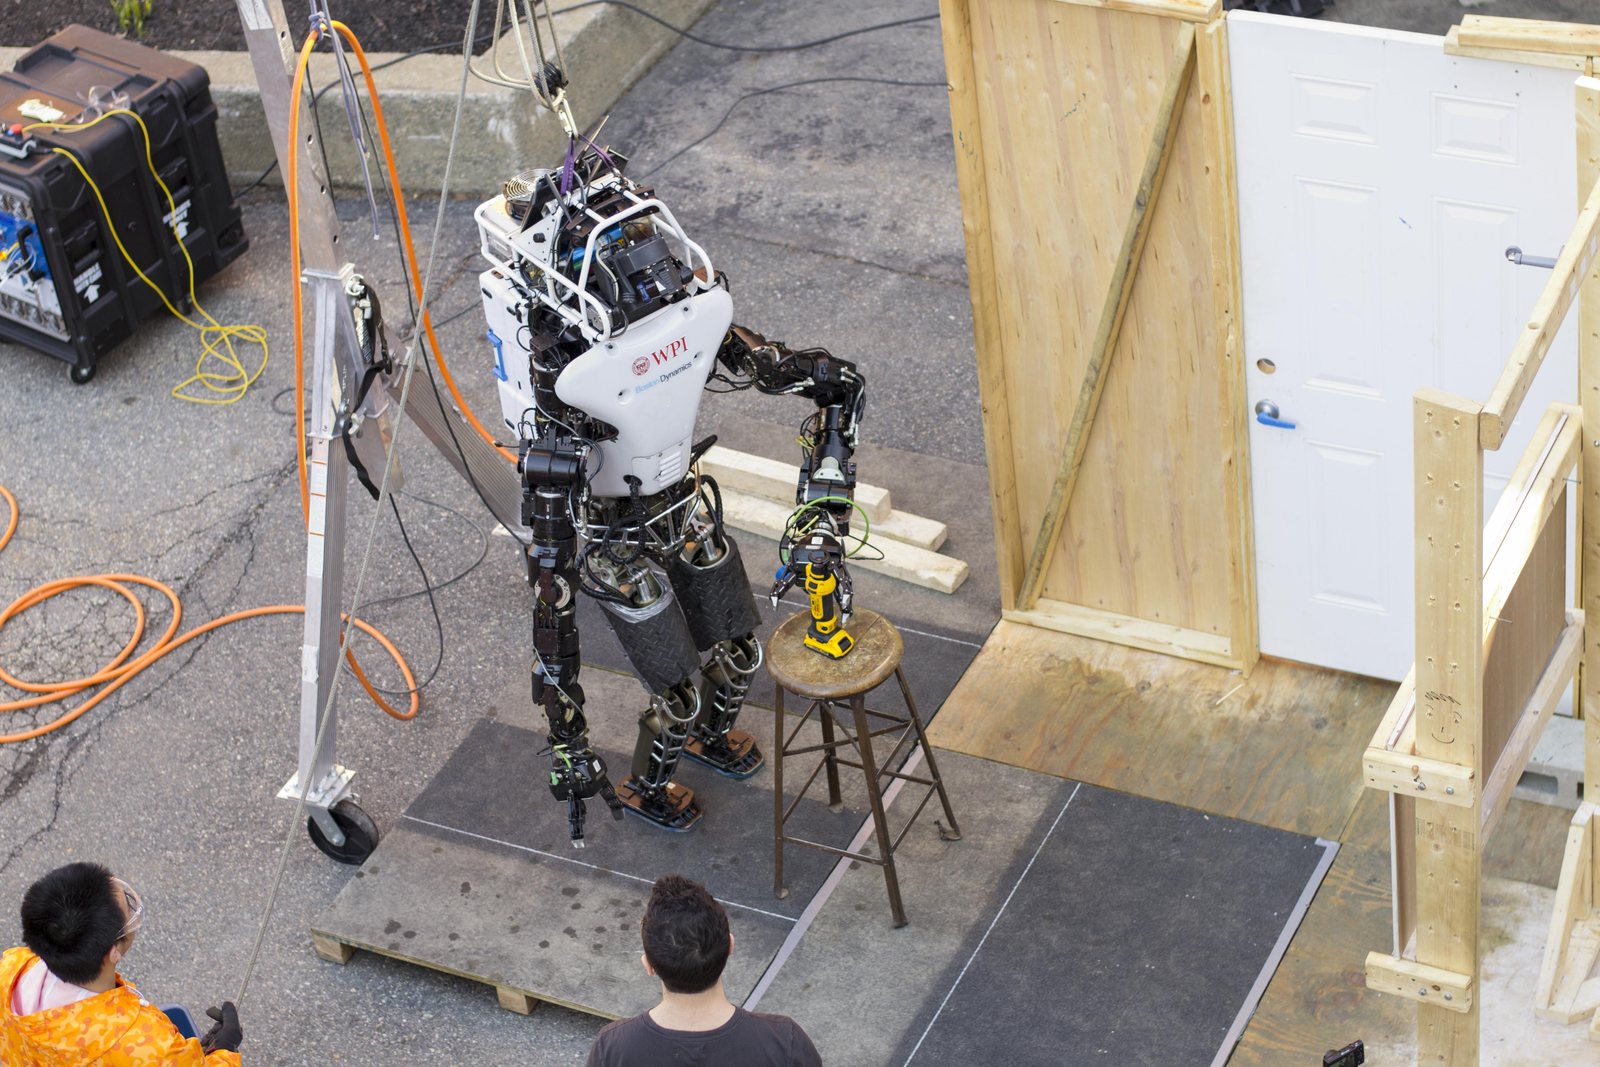
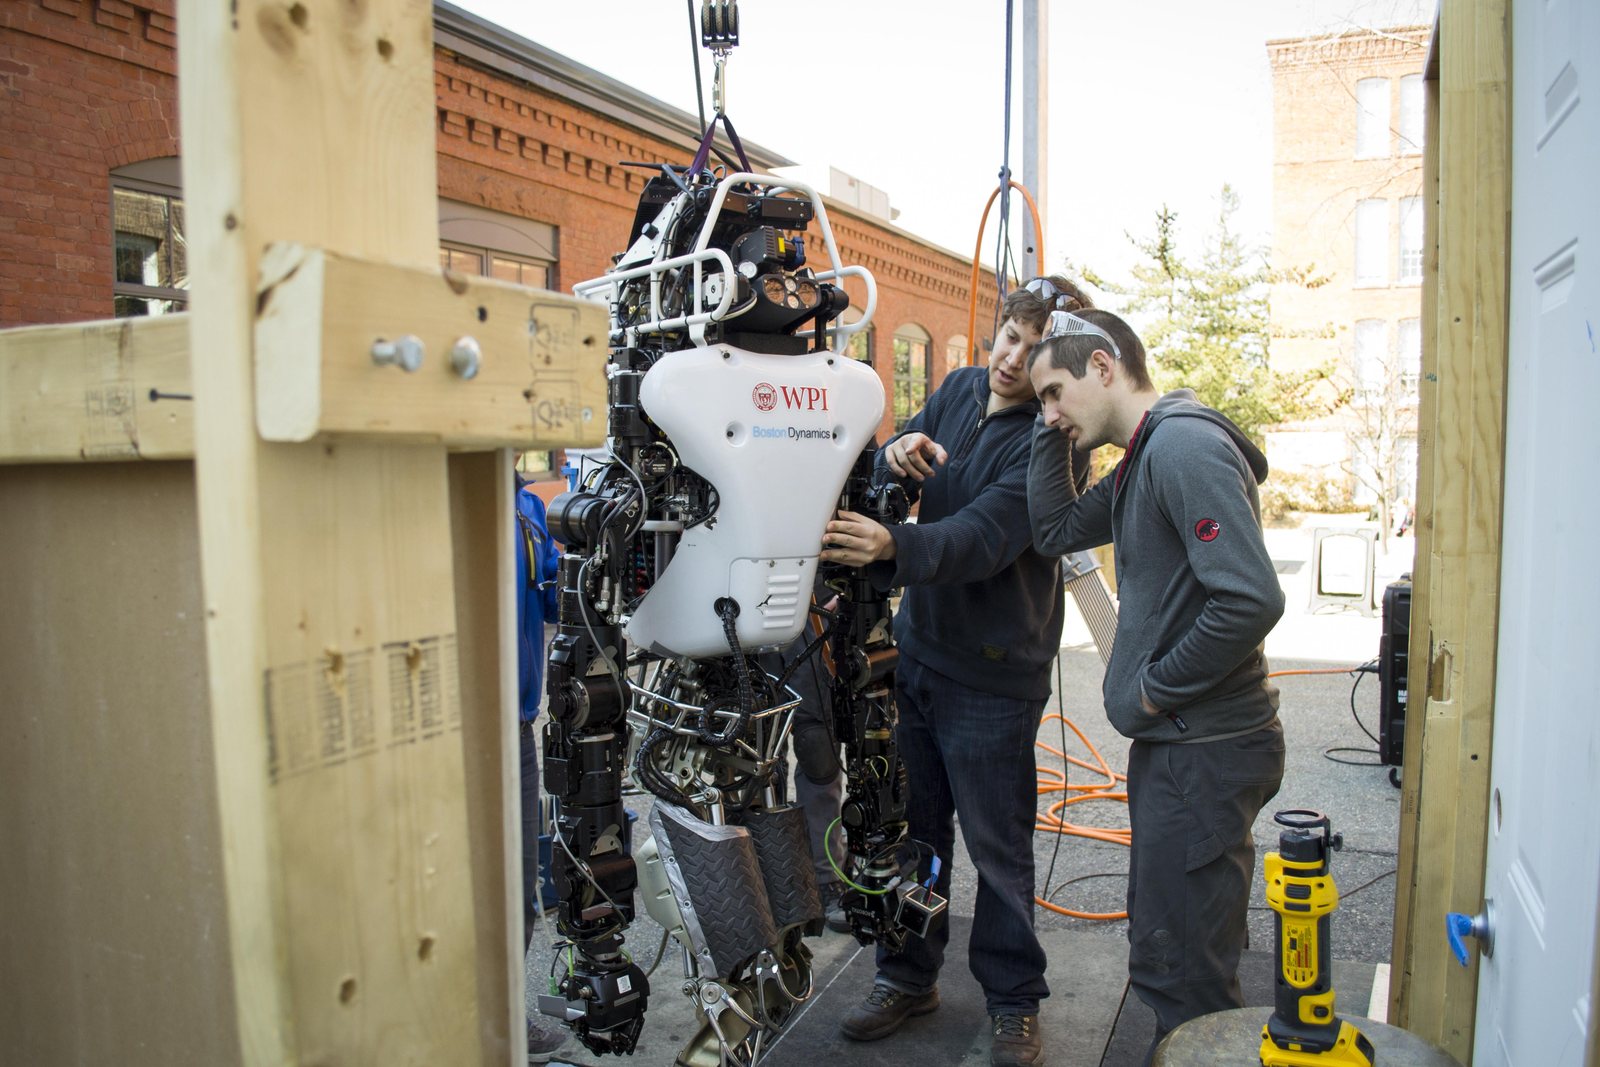
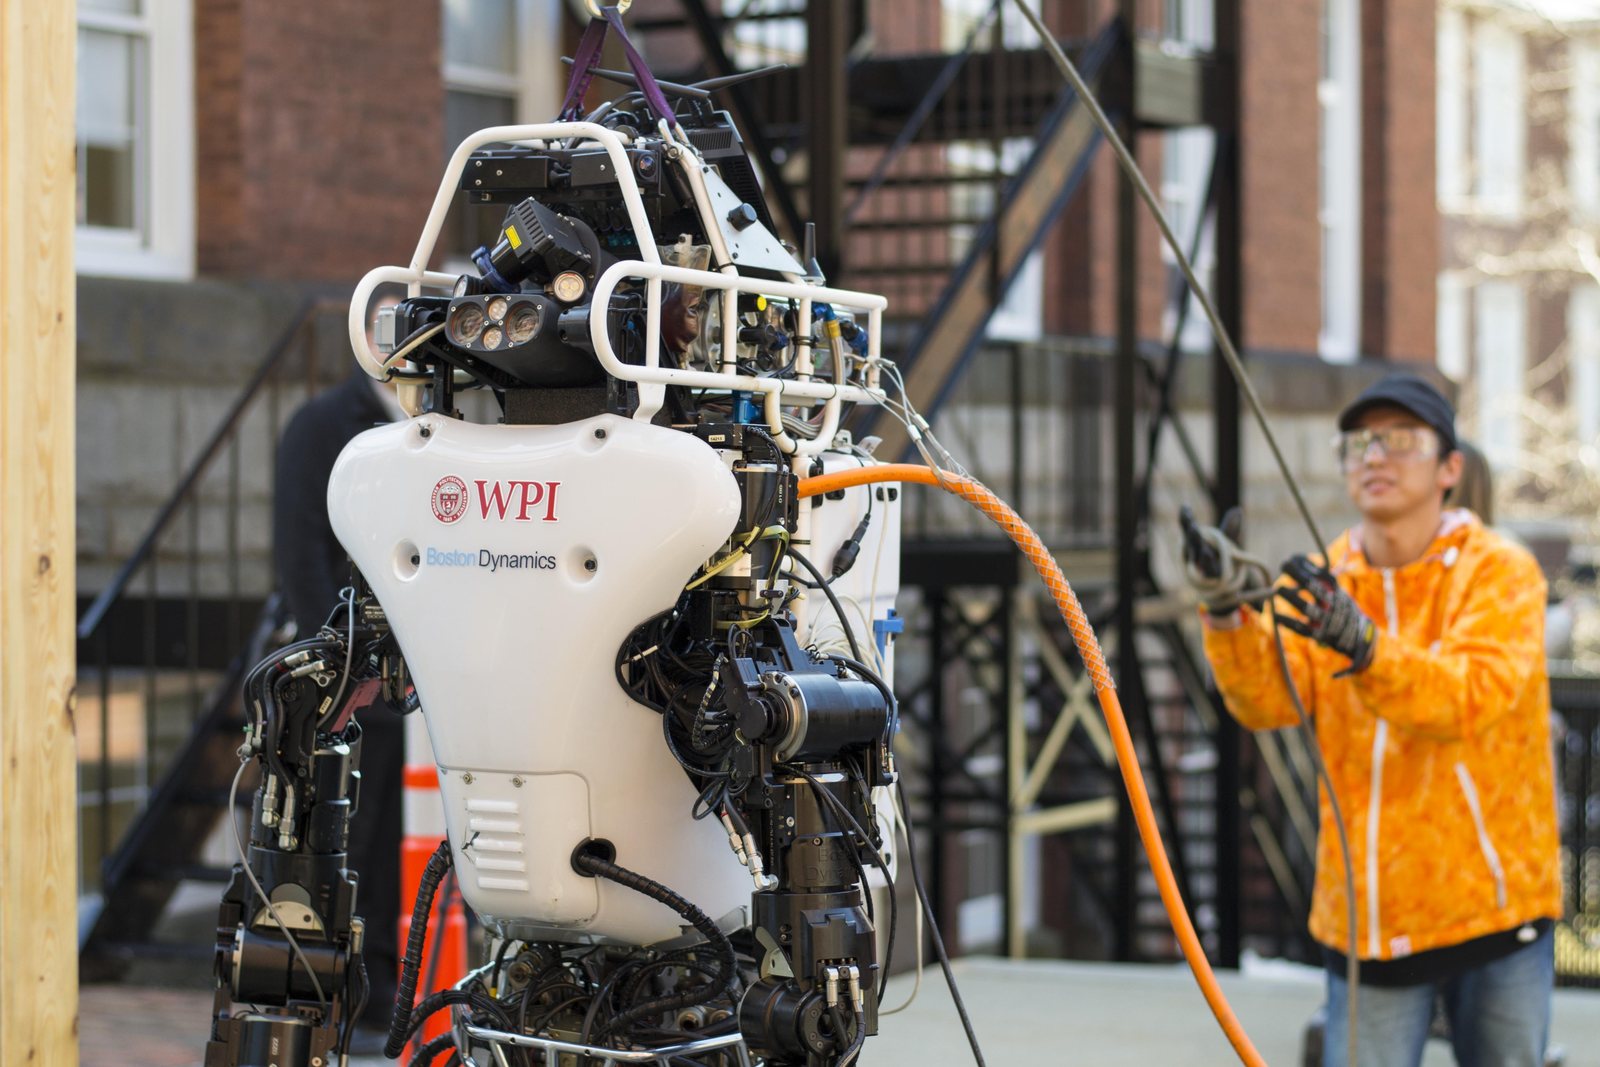
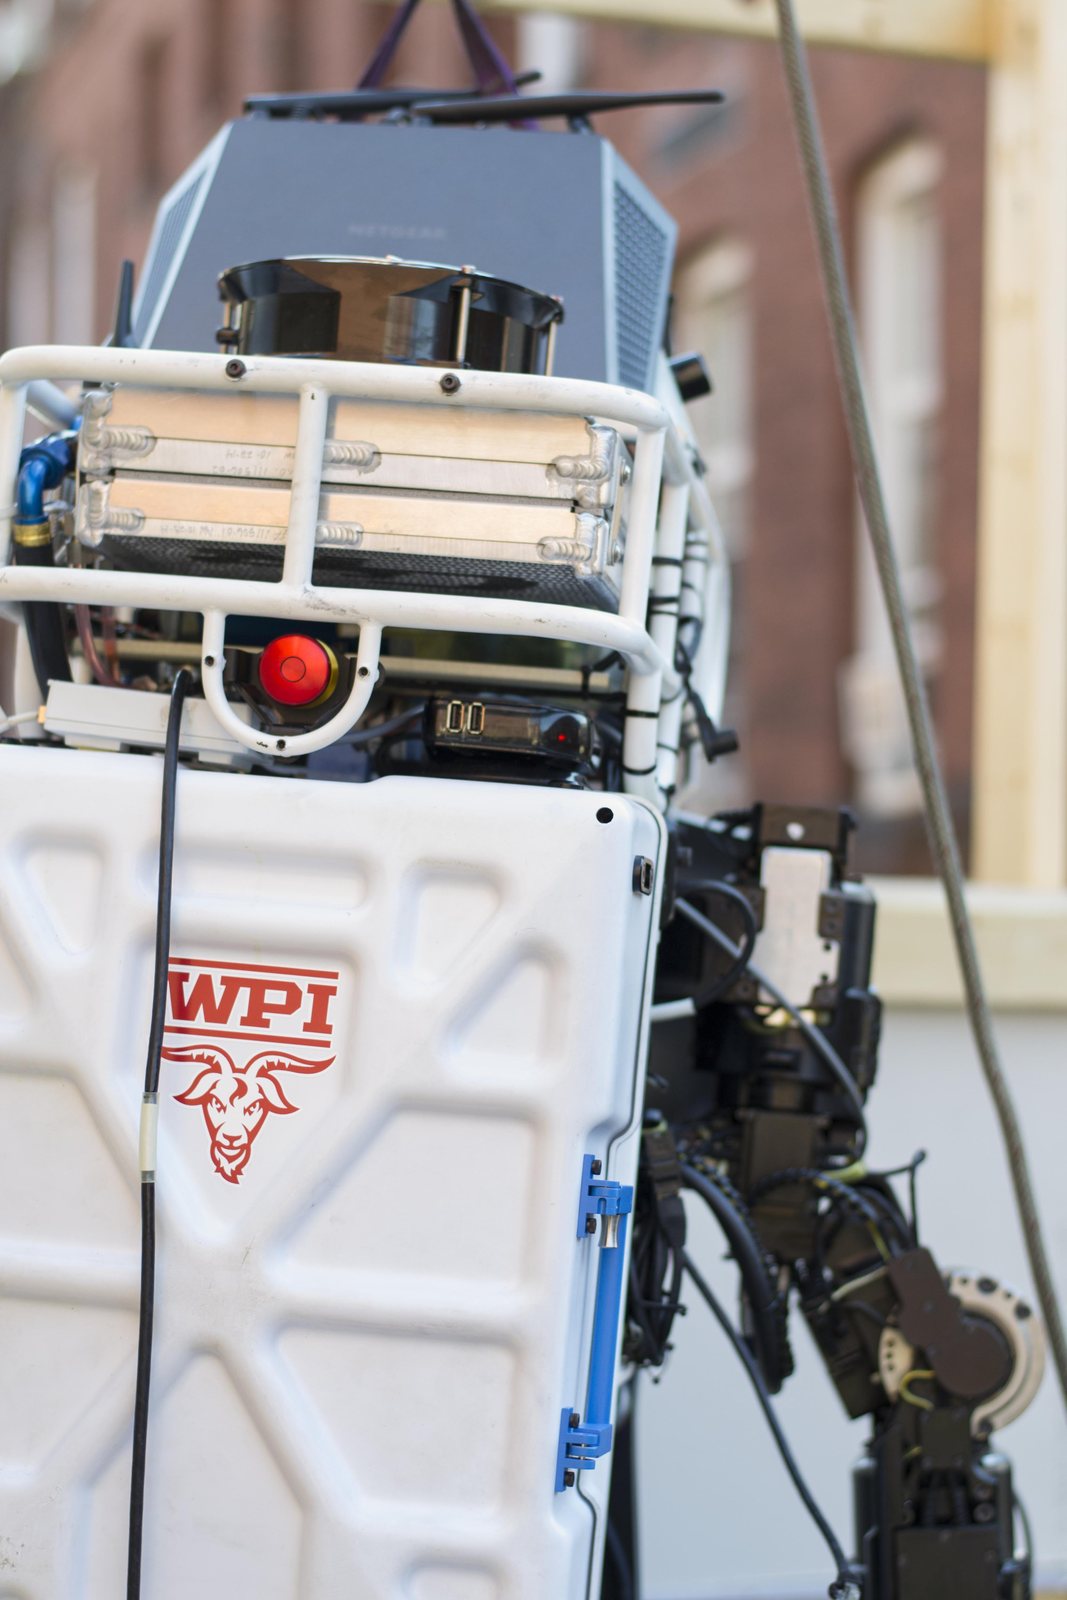
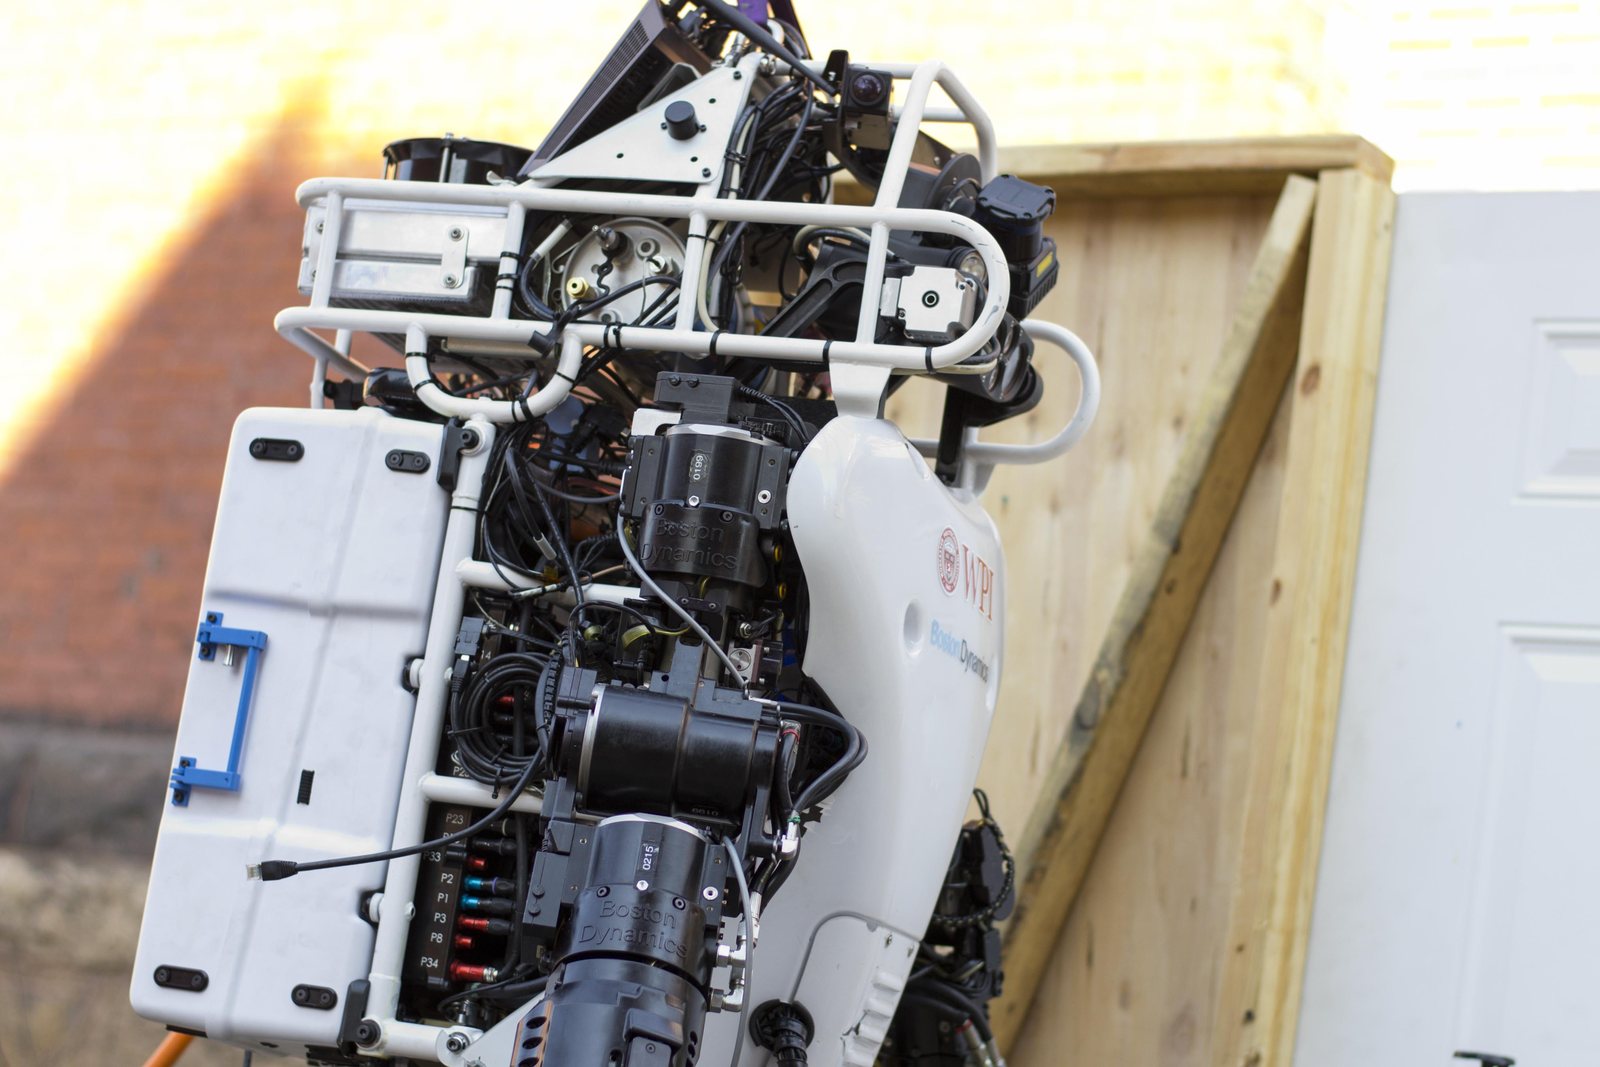
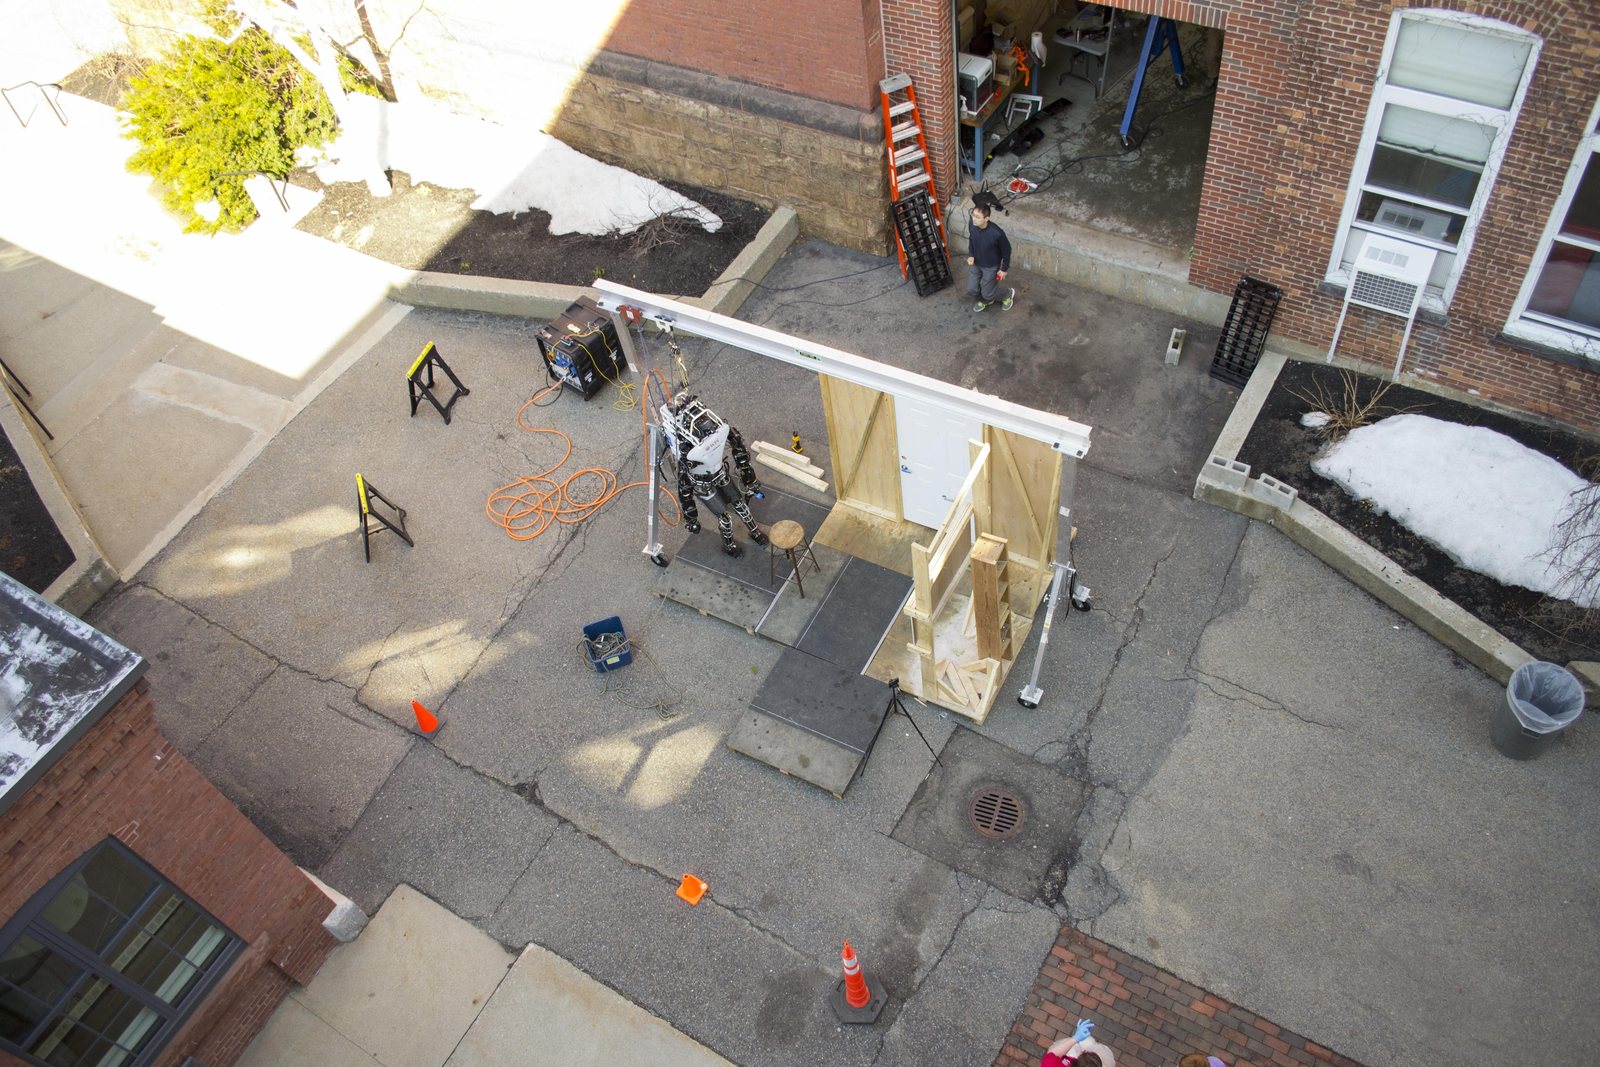
From the practice course behind the lab at WPI in the run-up to the Finals: the door task, tool grasping for the wall-cutting task, and walking trials with Atlas.
Outcomes
- Li, L., Long, X., & Gennert, M. A. (2016). BiRRTOpt: A combined sampling and optimizing motion planner for humanoid robots. 2016 IEEE-RAS 16th International Conference on Humanoid Robots (Humanoids), 469–476. https://doi.org/10.1109/HUMANOIDS.2016.7803317
- Atkeson, C. G., Babu, B. P. W., Banerjee, N., Berenson, D., Bove, C. P., Cui, X., DeDonato, M., Du, R., Feng, S., Franklin, P., & others. (2015). No falls, no resets: Reliable humanoid behavior in the DARPA Robotics Challenge. 2015 IEEE-RAS 15th International Conference on Humanoid Robots (Humanoids), 623–630. https://doi.org/10.1109/HUMANOIDS.2015.7363436
- DeDonato, M., Polido, F., Knoedler, K., Babu, B. P. W., Banerjee, N., Bove, C. P., Cui, X., Du, R., Franklin, P., Graff, J. P., & others. (2017). Team WPI-CMU: Achieving reliable humanoid behavior in the DARPA Robotics Challenge. Journal of Field Robotics, 34(2), 381–399. https://doi.org/10.1002/rob.21685
- Atkeson, C. G., Benzun, P. W. B., Banerjee, N., Berenson, D., Bove, C. P., Cui, X., DeDonato, M., Du, R., Feng, S., Franklin, P., & others. (2018). What happened at the DARPA Robotics Challenge Finals. In M. Spenko, S. Buerger, & K. Iagnemma (Eds.), The DARPA Robotics Challenge Finals: Humanoid Robots to the Rescue (Vol. 121, pp. 667–684). Springer. https://doi.org/10.1007/978-3-319-74666-1_17
- Atkeson, C. G., Benzun, P. W. B., Banerjee, N., Berenson, D., Bove, C. P., Cui, X., DeDonato, M., Du, R., Feng, S., Franklin, P., & others. (2018). Achieving reliable humanoid robot operations in the DARPA Robotics Challenge: Team WPI-CMU’s approach. In M. Spenko, S. Buerger, & K. Iagnemma (Eds.), The DARPA Robotics Challenge Finals: Humanoid Robots to the Rescue (Vol. 121, pp. 271–307). Springer. https://doi.org/10.1007/978-3-319-74666-1_8