Anytime Planning via Function Approximation and Importance Sampling
Motion planning for nonlinear robotic systems is computationally intractable in general (PSPACE-hard), so approximate schemes — discretization-based (A*) and sampling-based (RRT*) — dominate practice. We explore a third approach: function approximation, which transforms planning in the state space into planning in a low-dimensional parameter space of policy function approximators.
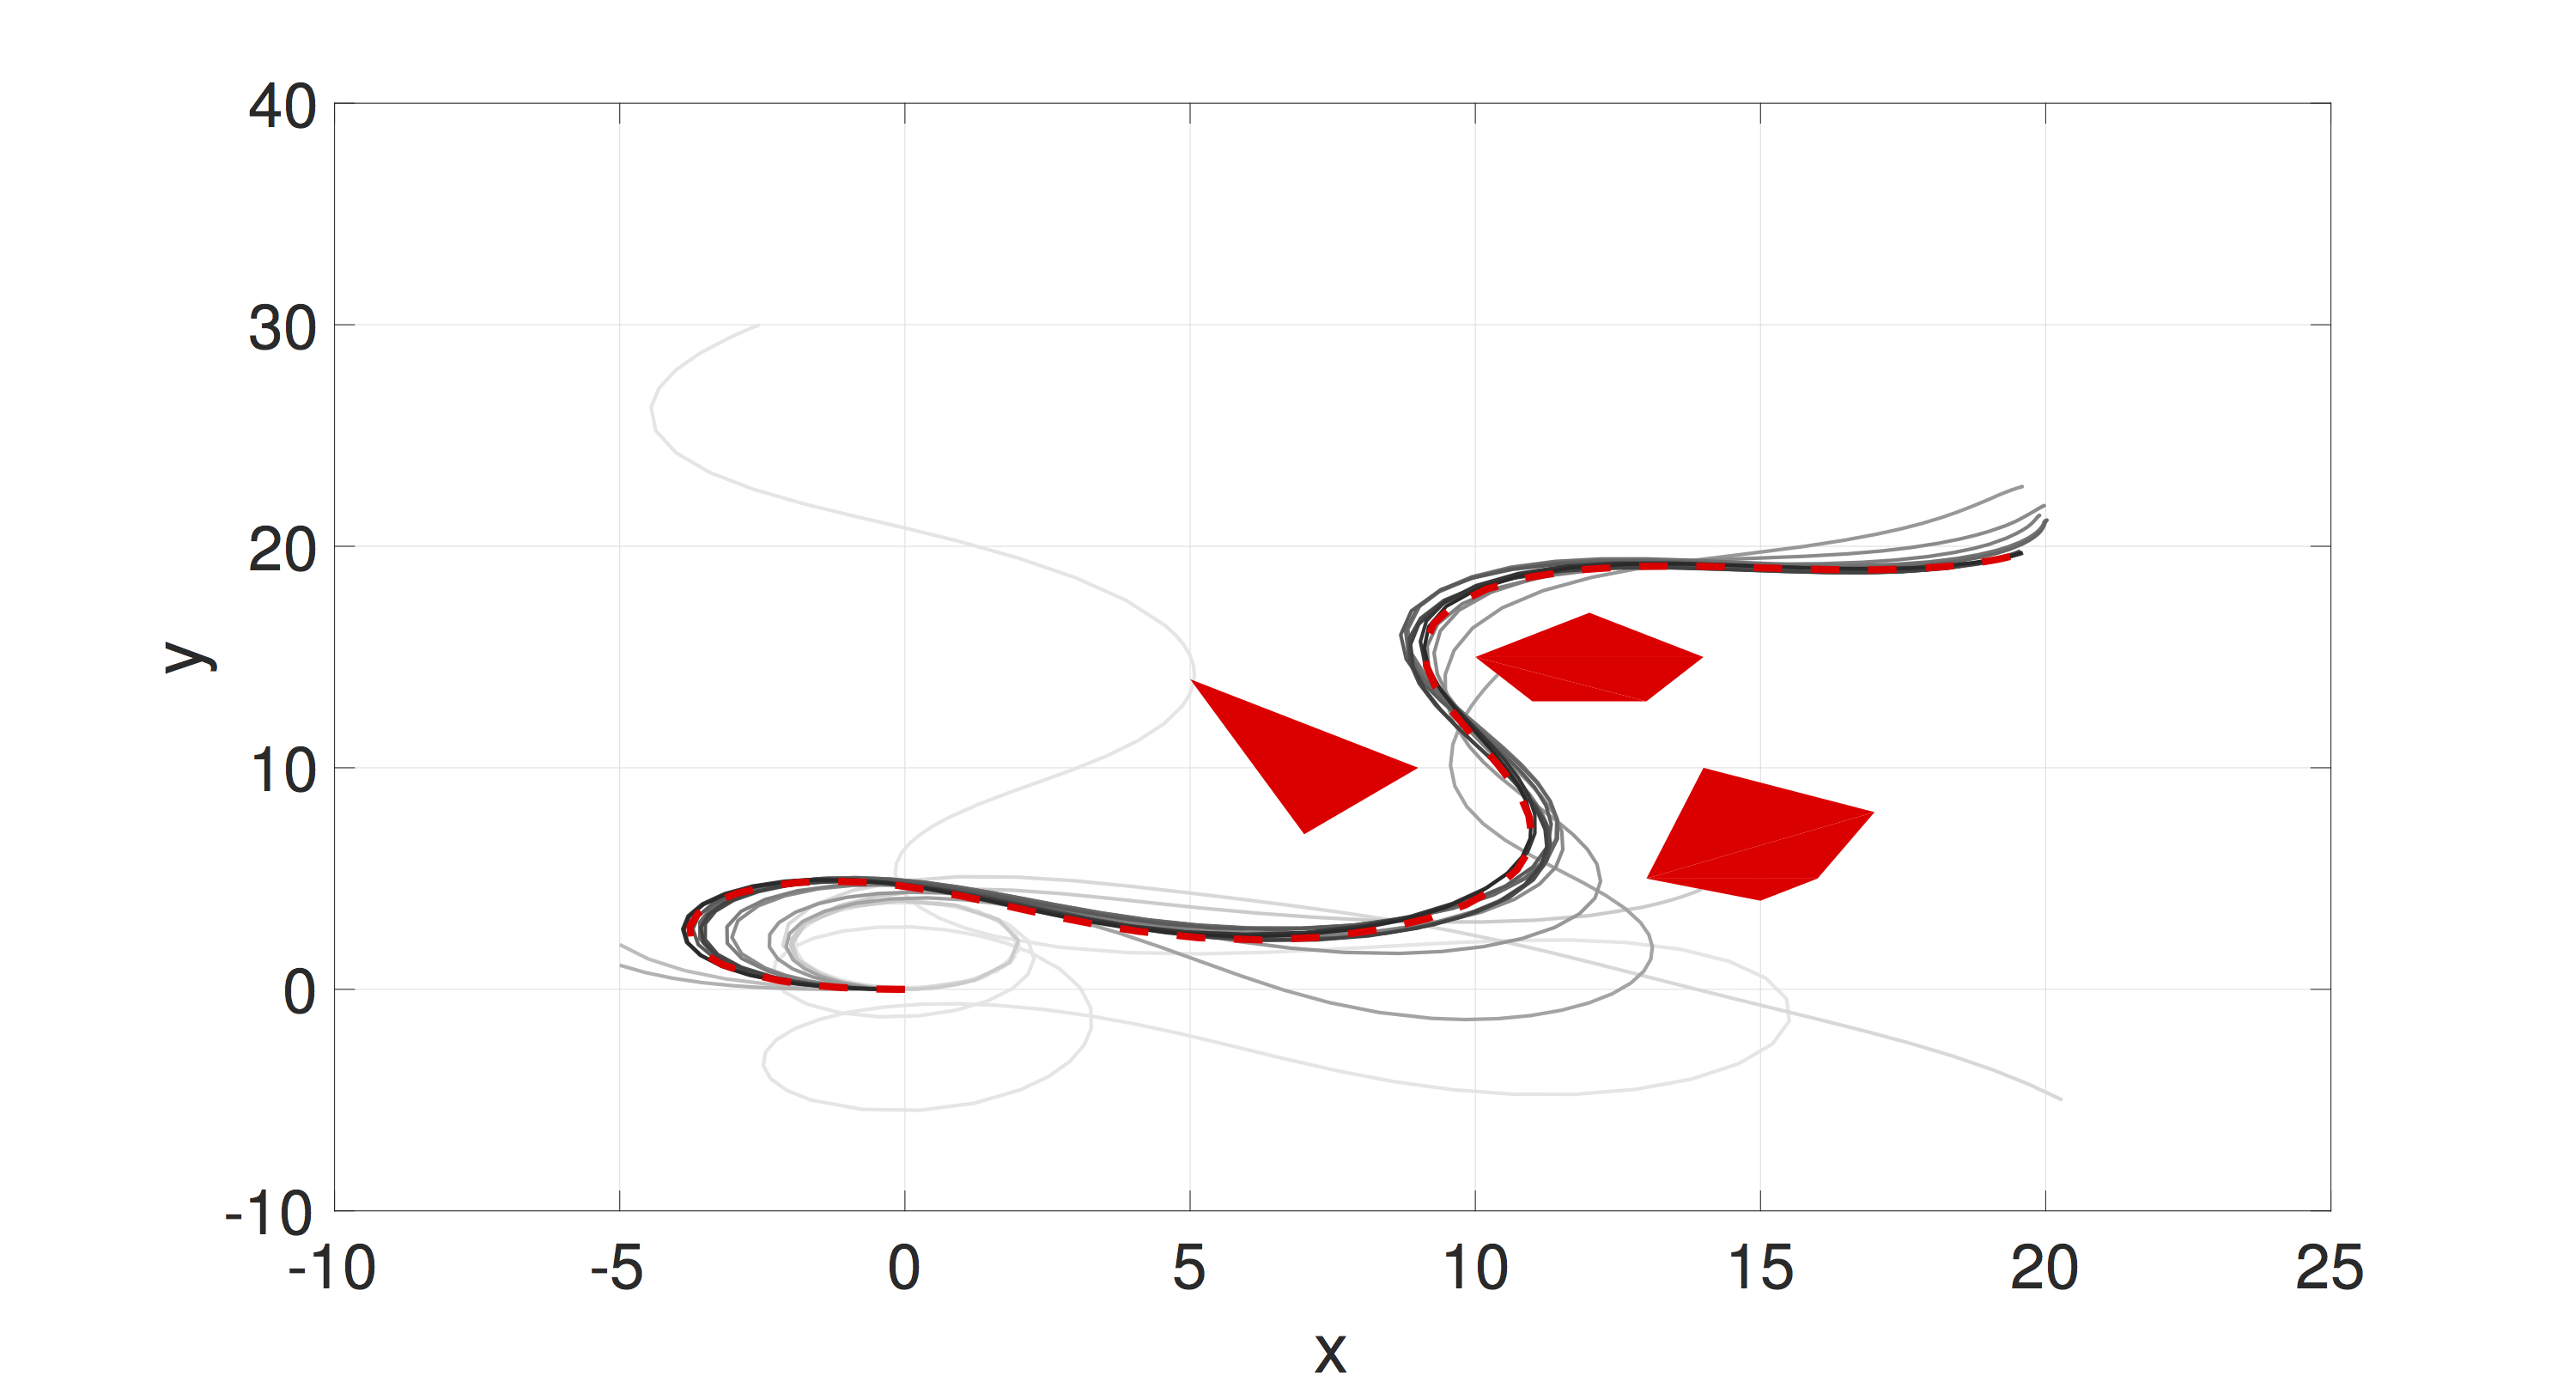
We use importance sampling to search efficiently for the optimal feedback policy. The algorithm supports parallel computation and anytime planning, making it a natural fit for cloud robotics and GPU-accelerated planning.
Outcomes
- Li, L., & Fu, J. (2017). Sampling-based approximate optimal temporal logic planning. 2017 IEEE International Conference on Robotics and Automation (ICRA), 1328–1335. https://doi.org/10.1109/ICRA.2017.7989157